Neptune — Edge-to-Cloud Marine Data & Media Pipeline
January 2023 | Client: MyW.AI
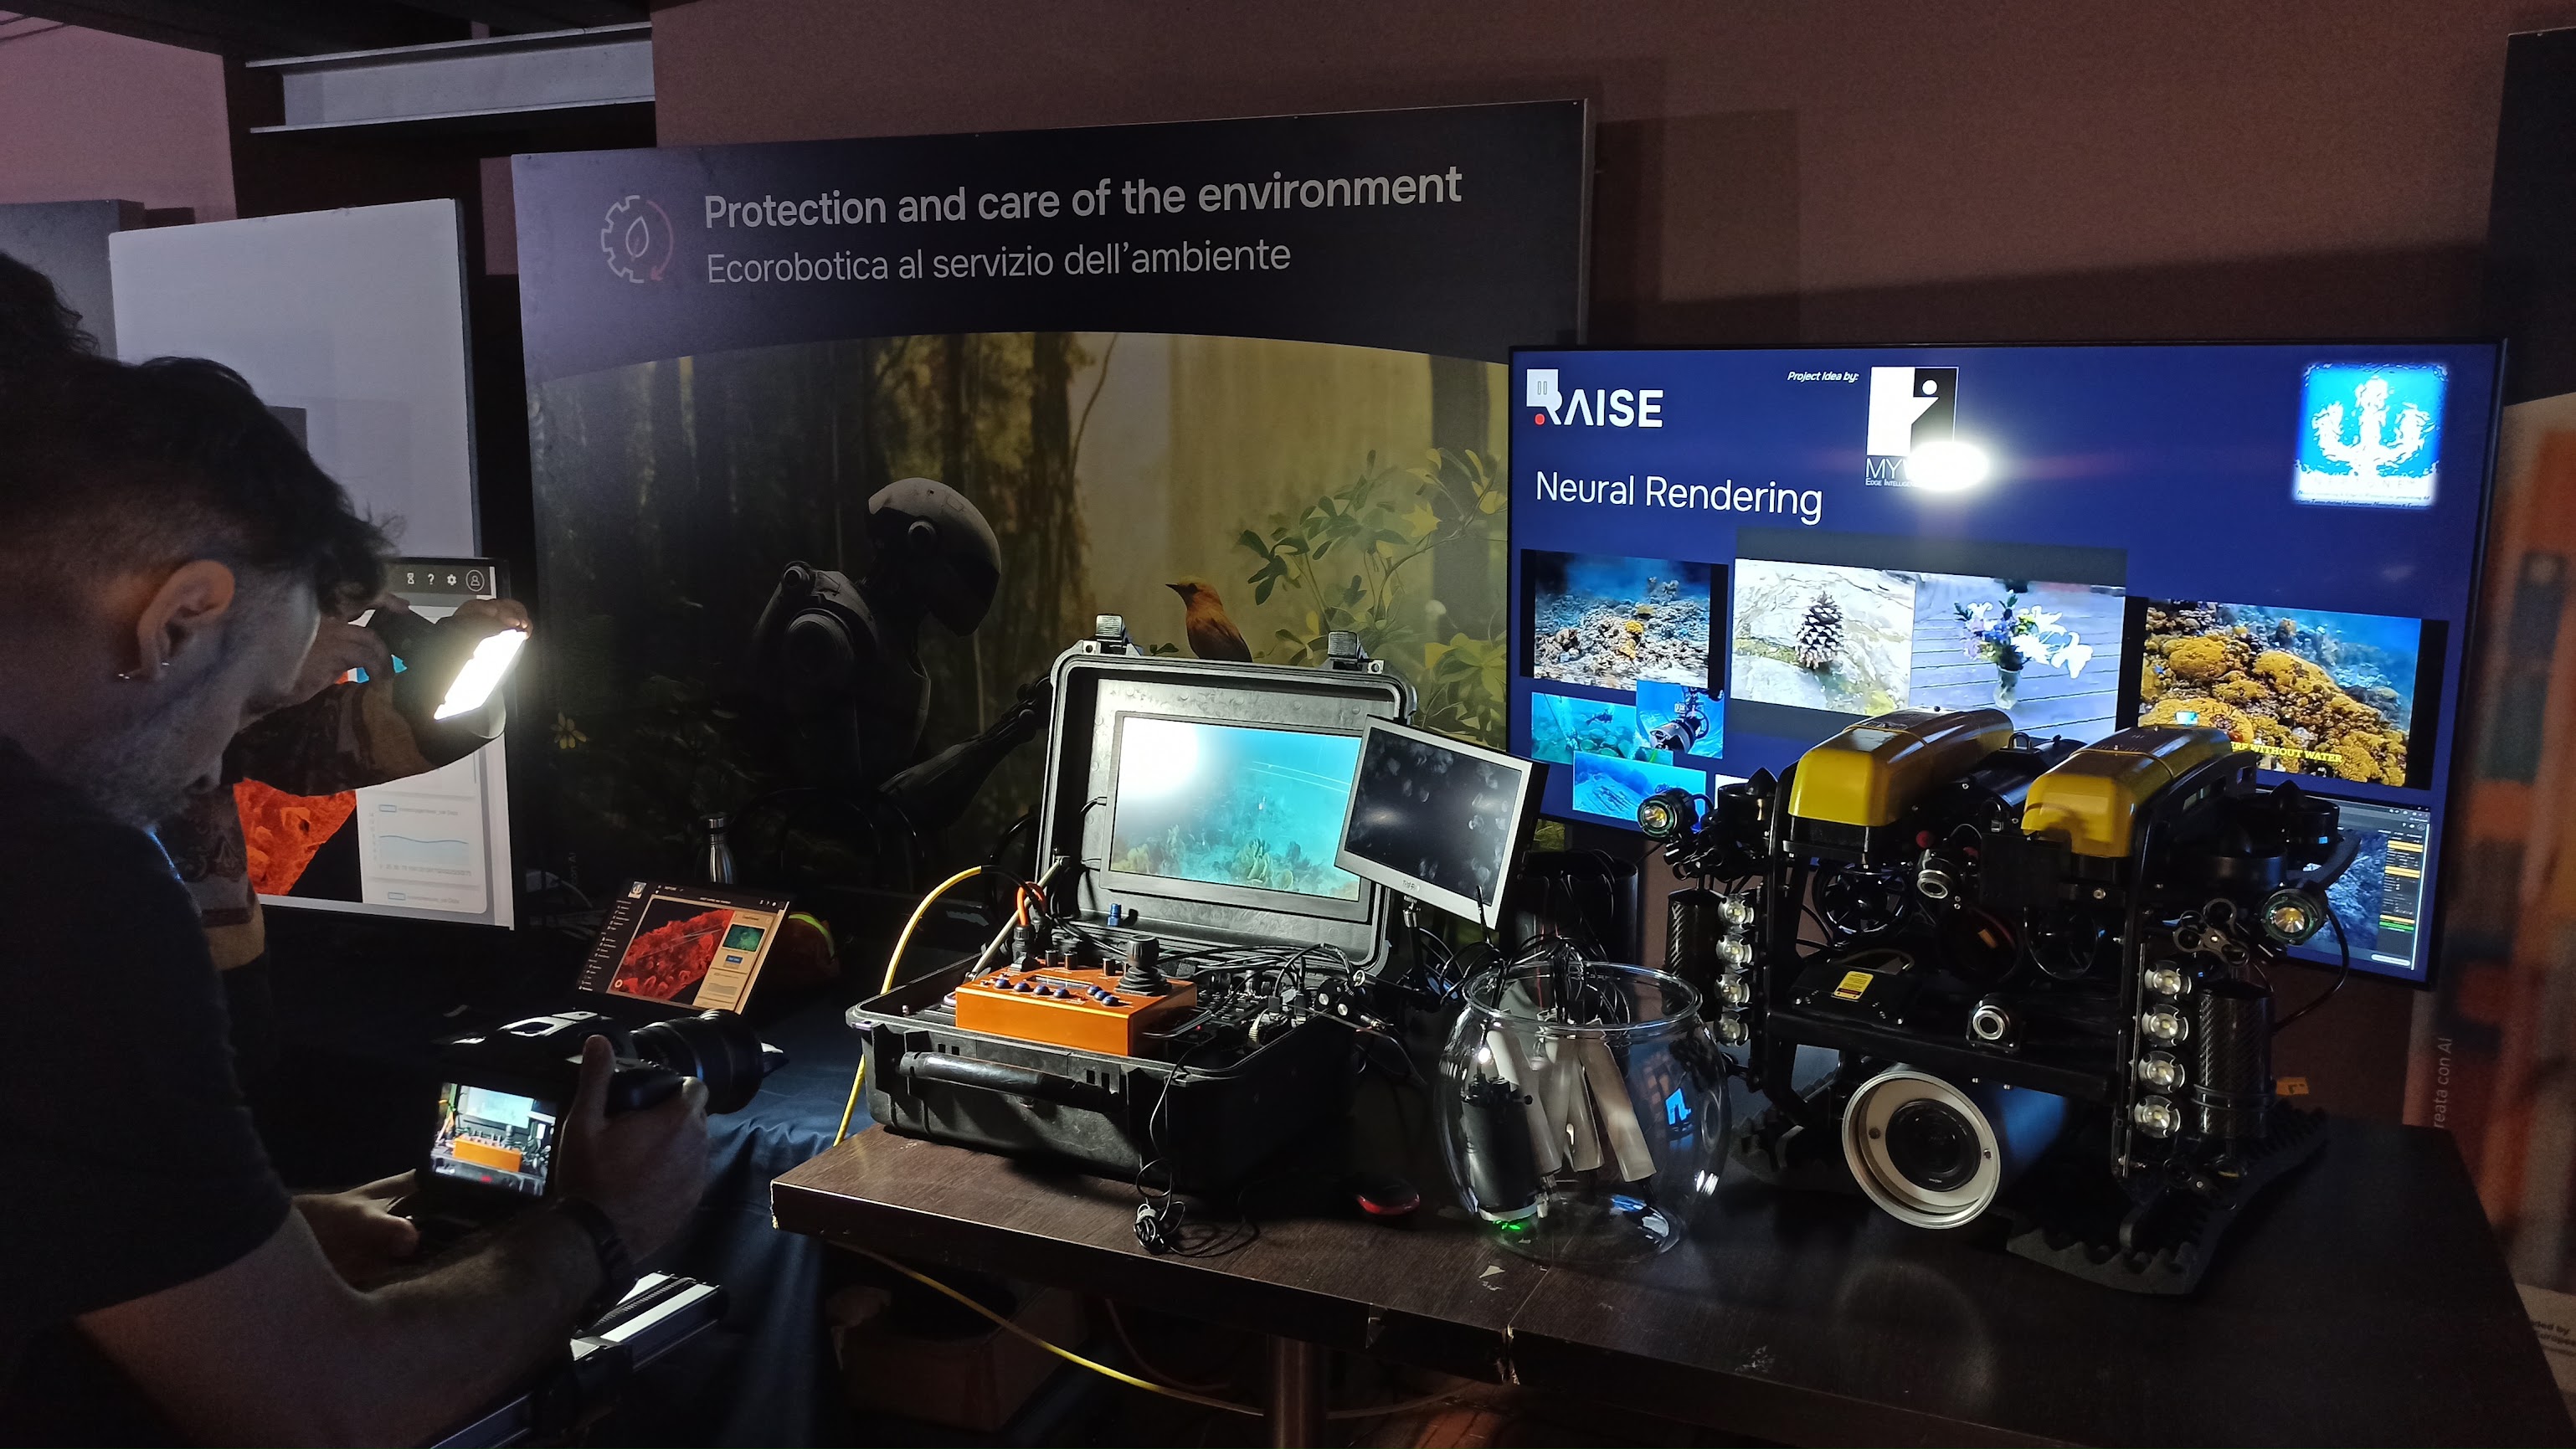
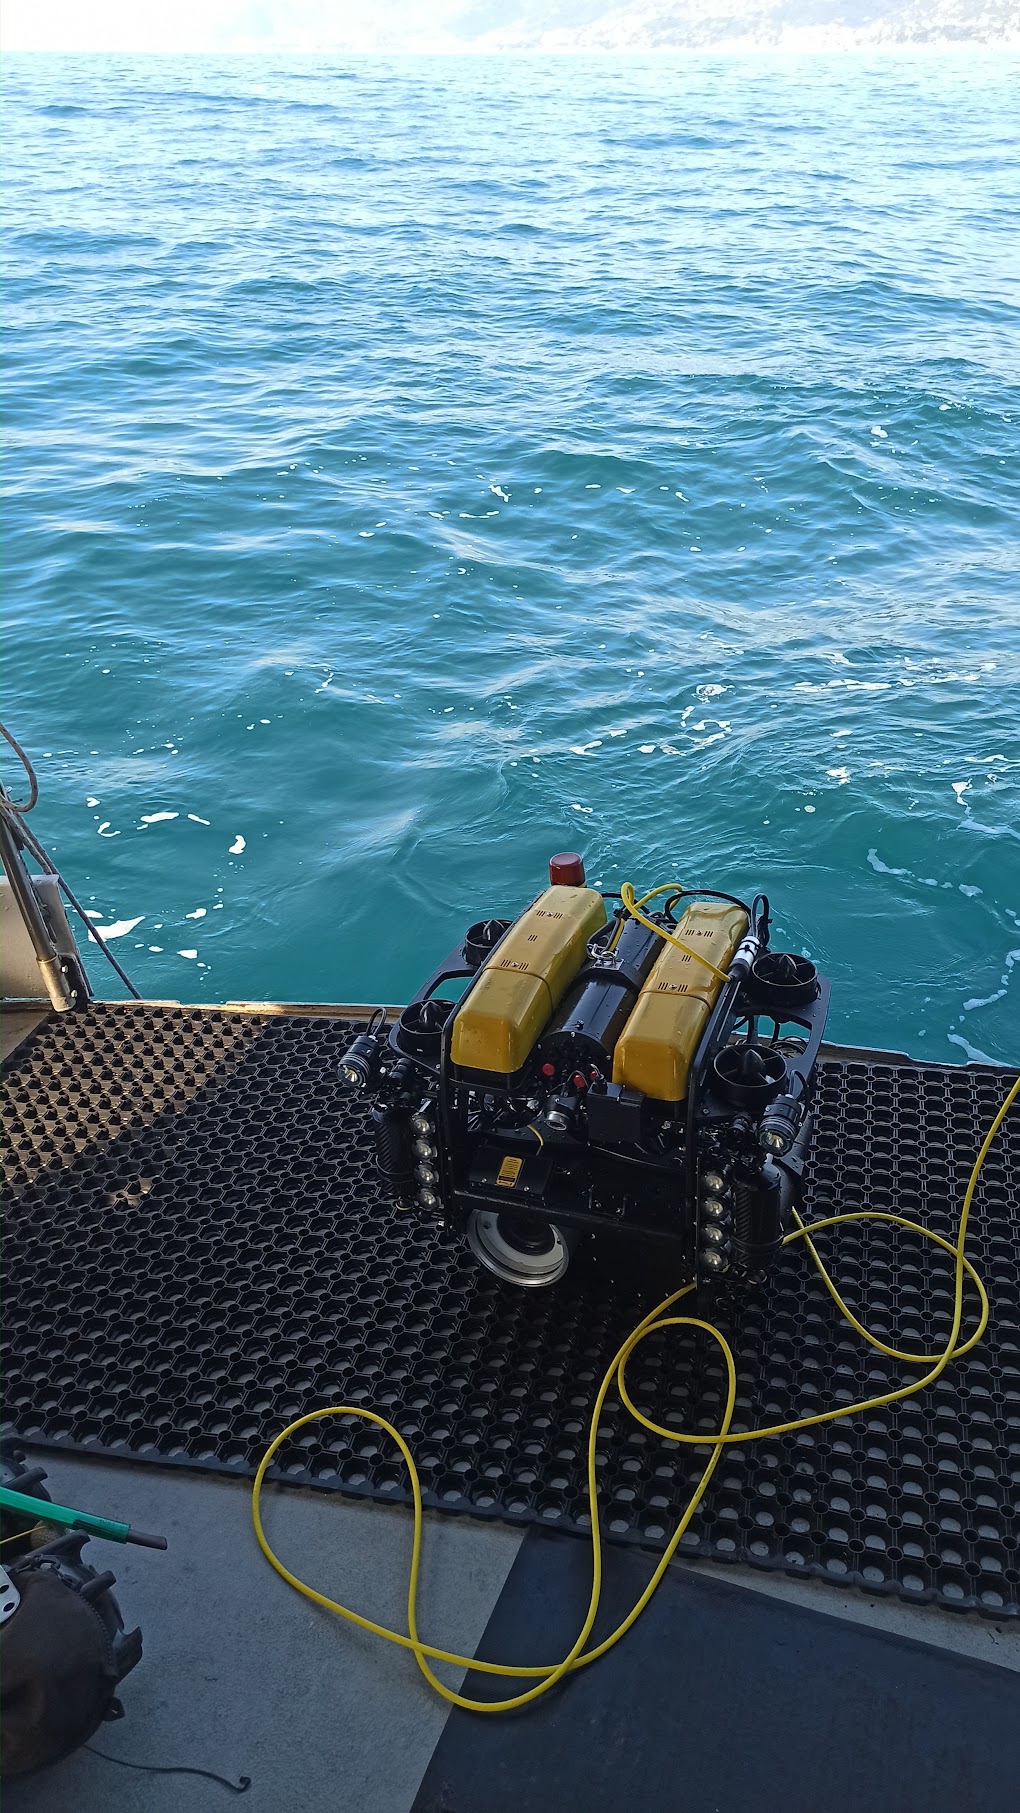
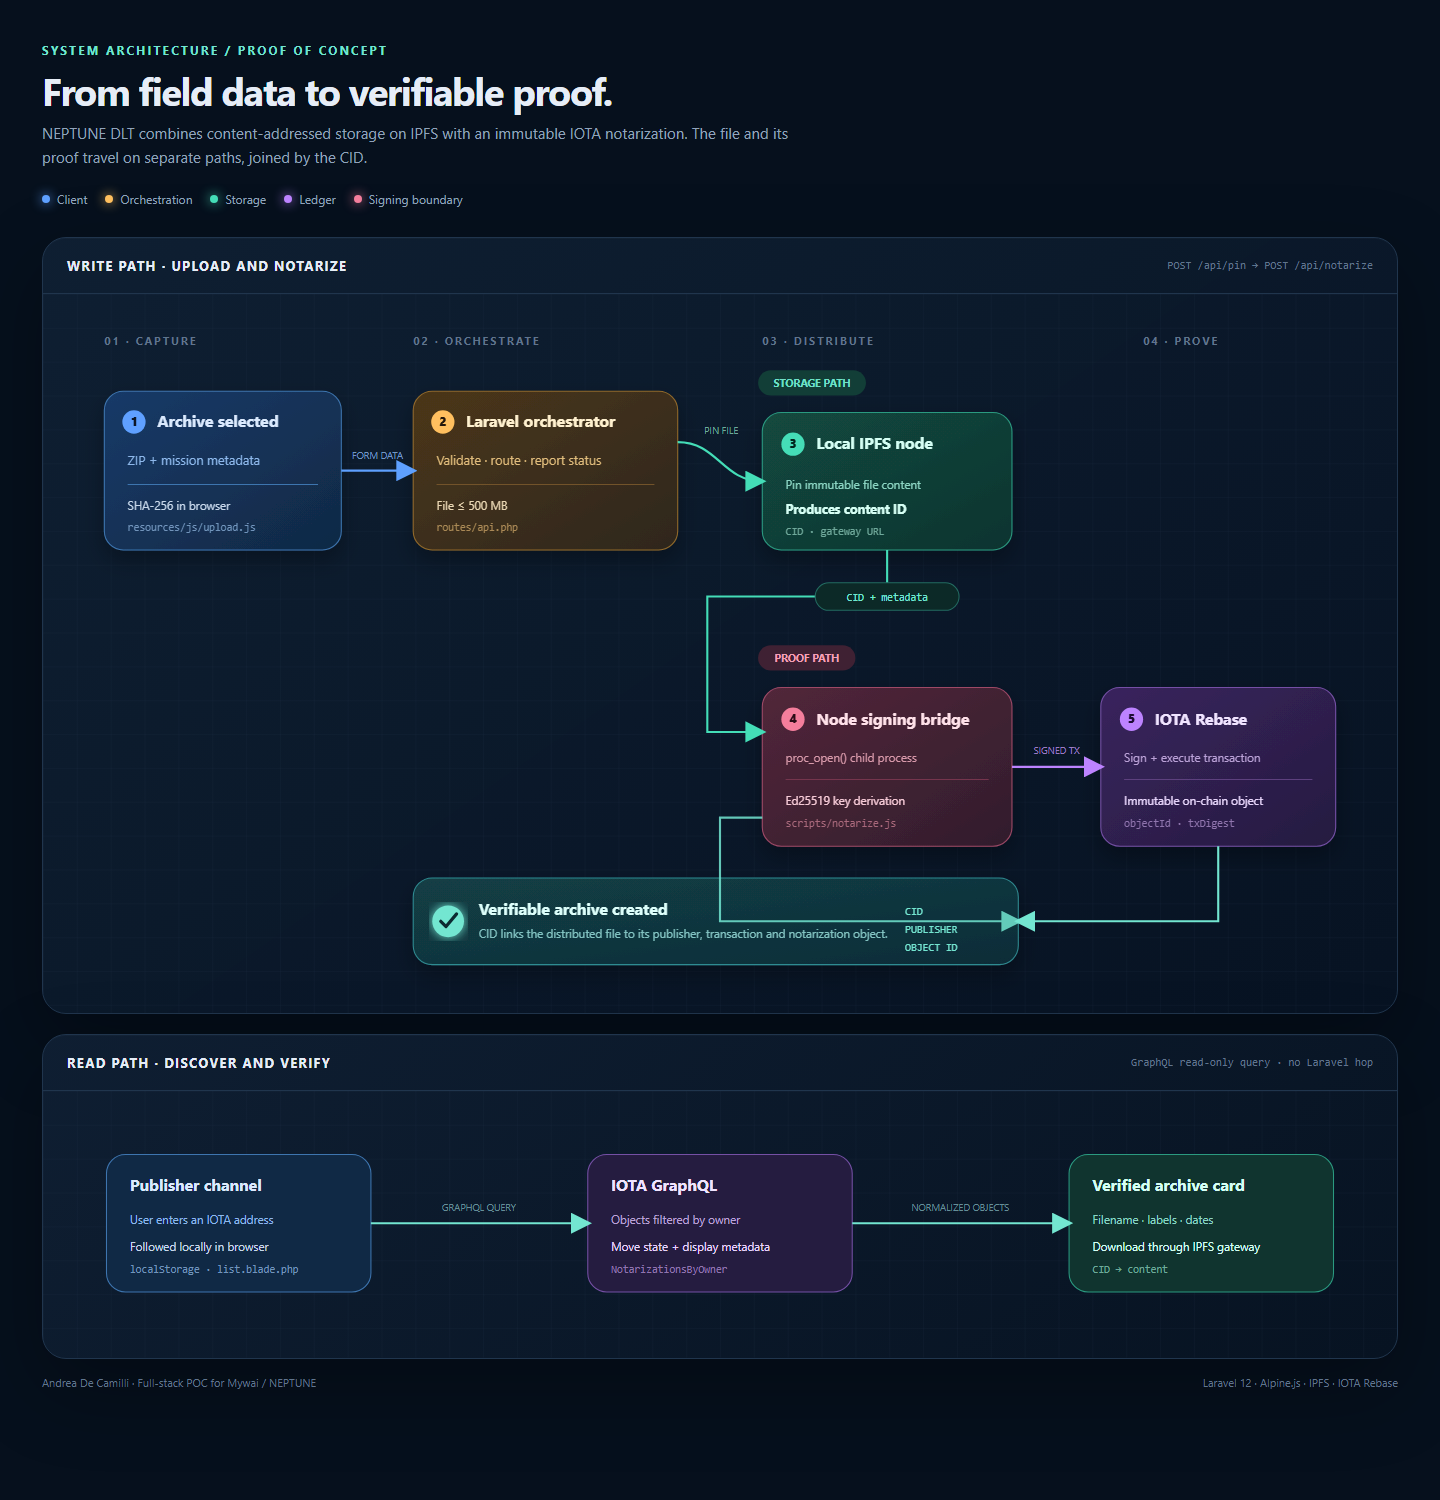
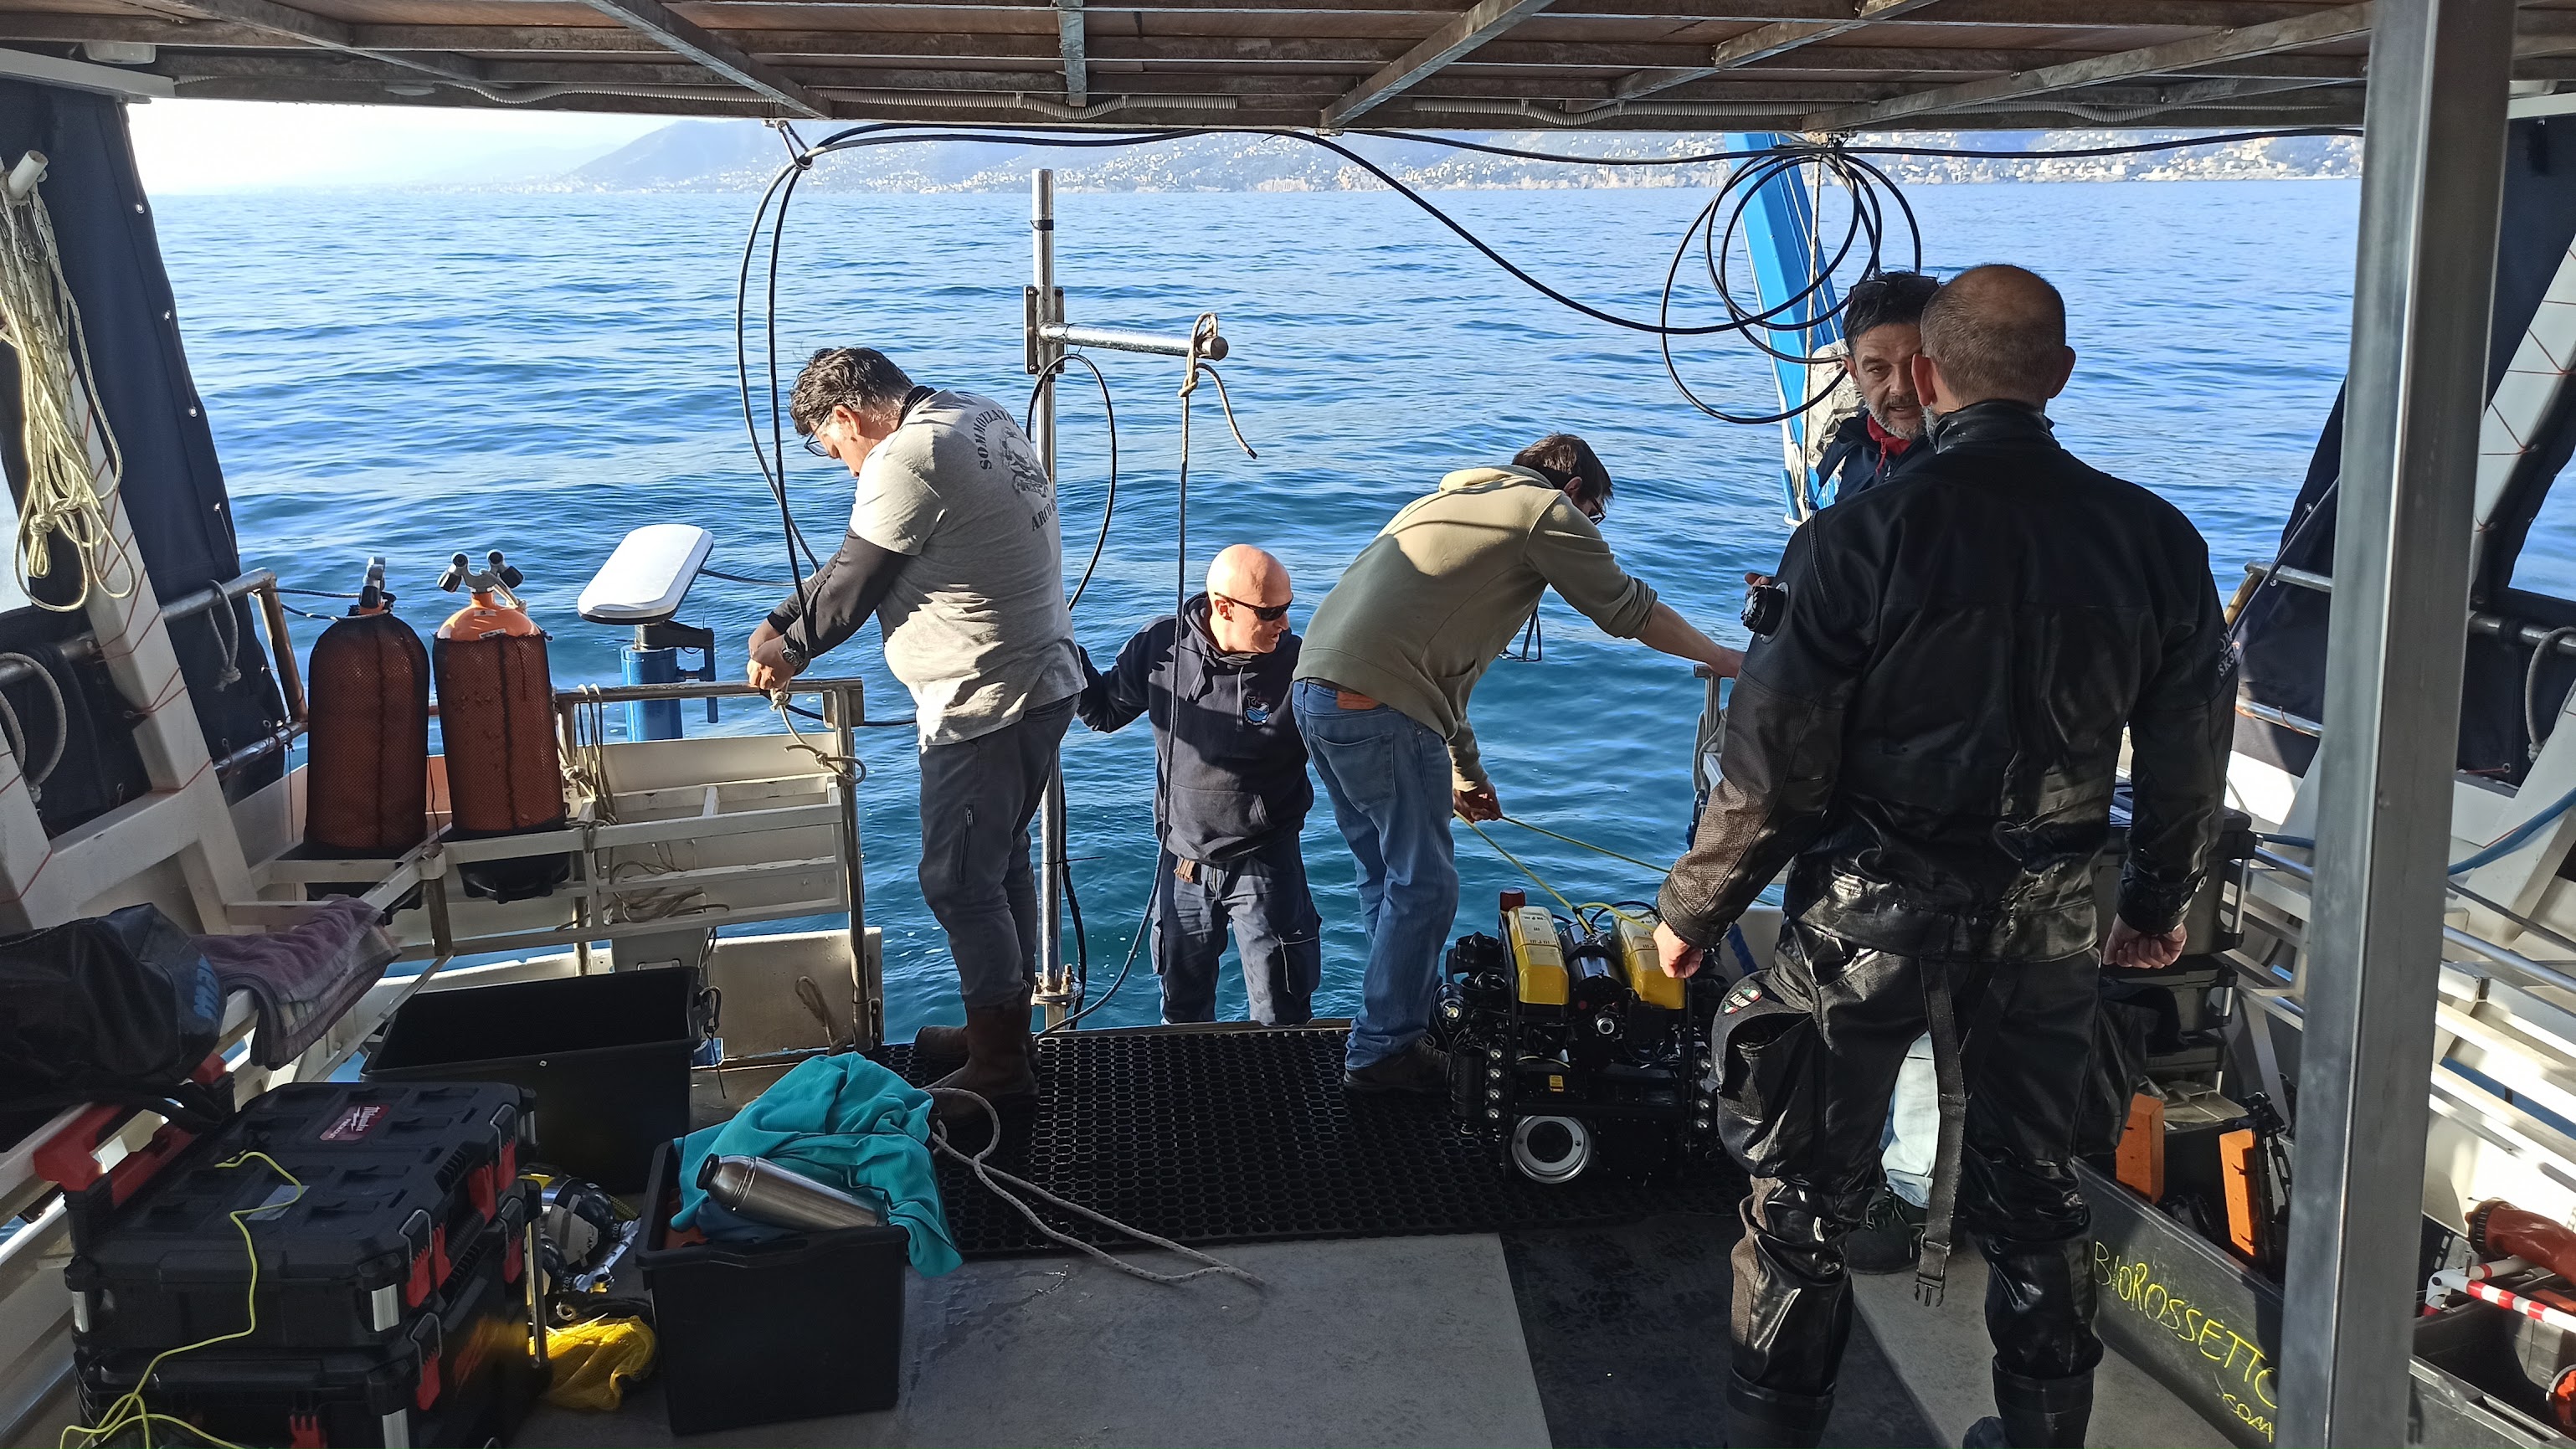
NEPTUNE was an end-to-end edge-to-cloud system for underwater missions, connecting ROV and DPV payloads, environmental sensors, camera streams and remote operational monitoring. The project combined an OceanPulse sensor platform, a ruggedized camera and electronics stack, OPC UA data modelling, MQTT telemetry, an interactive Laravel dashboard and video relays based on RTSP, RTMP and FFmpeg.
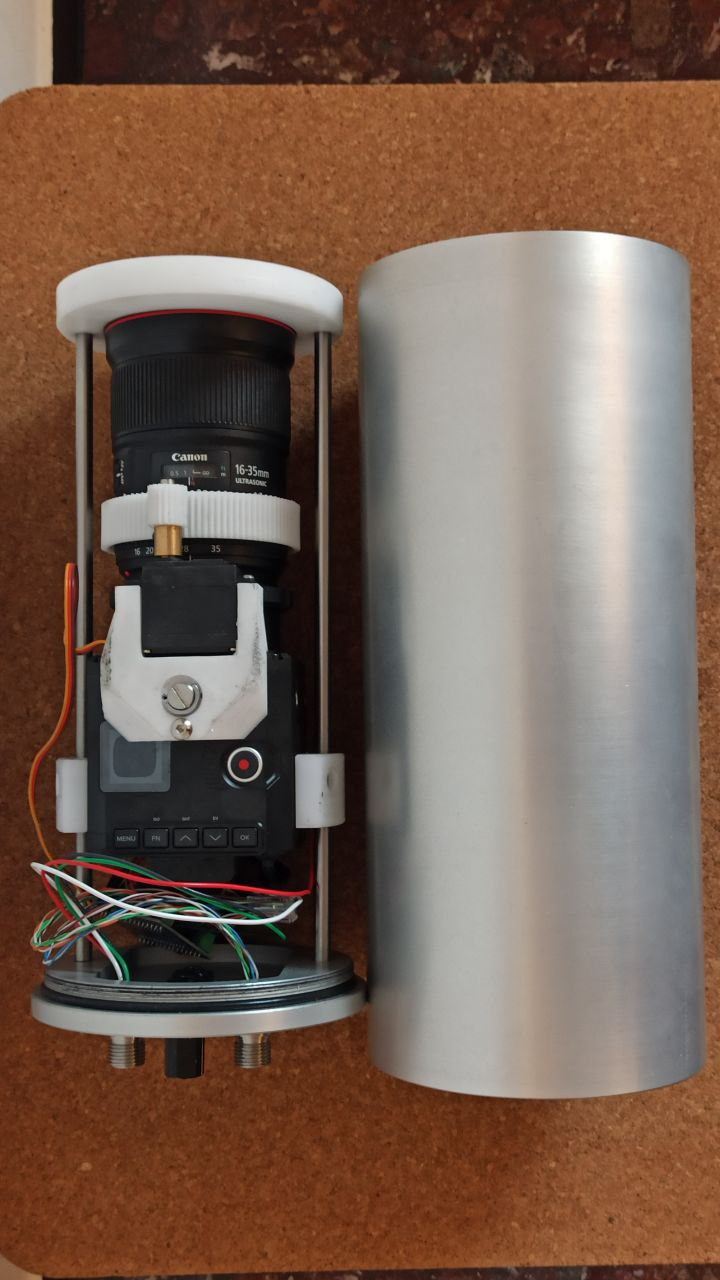
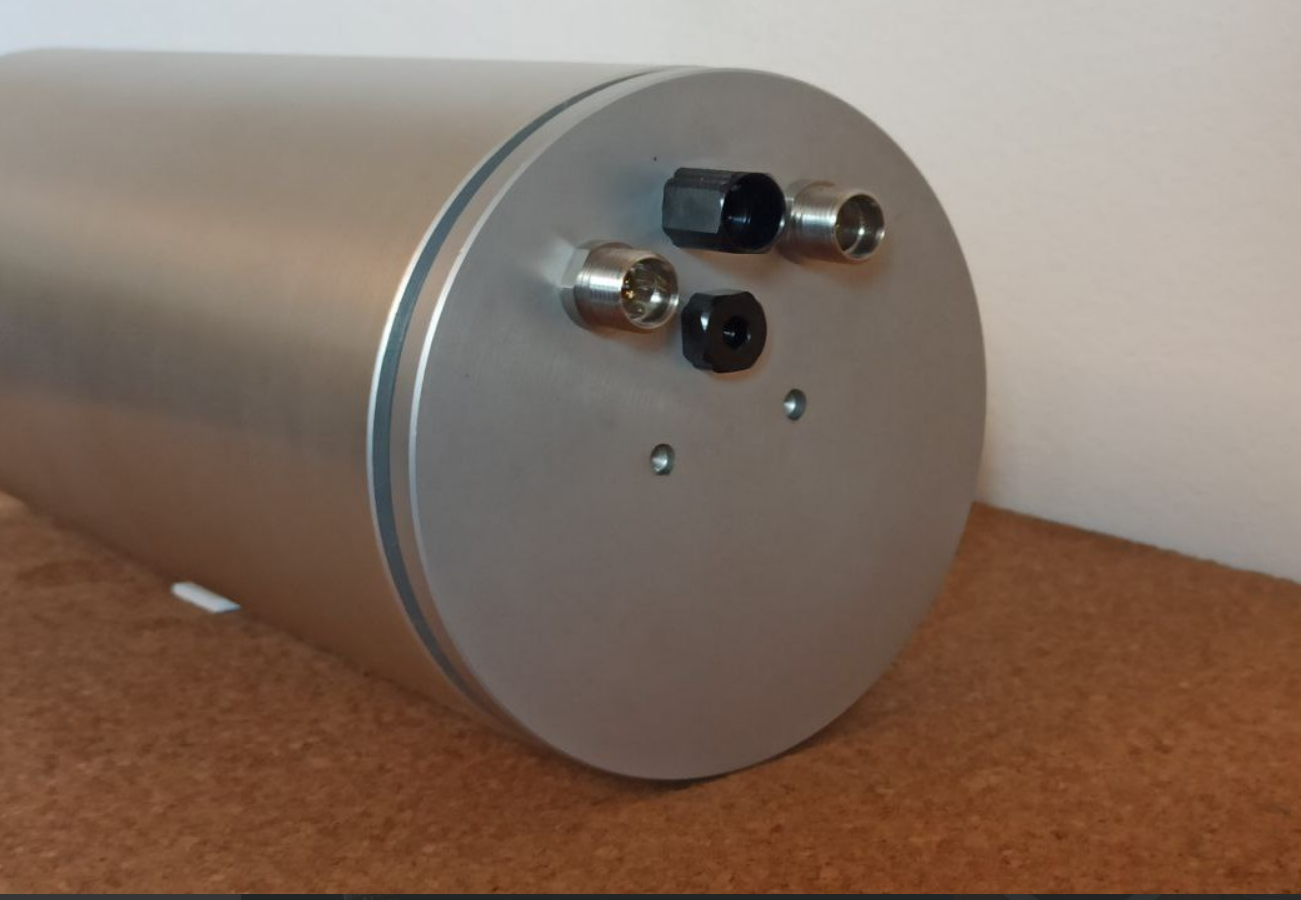
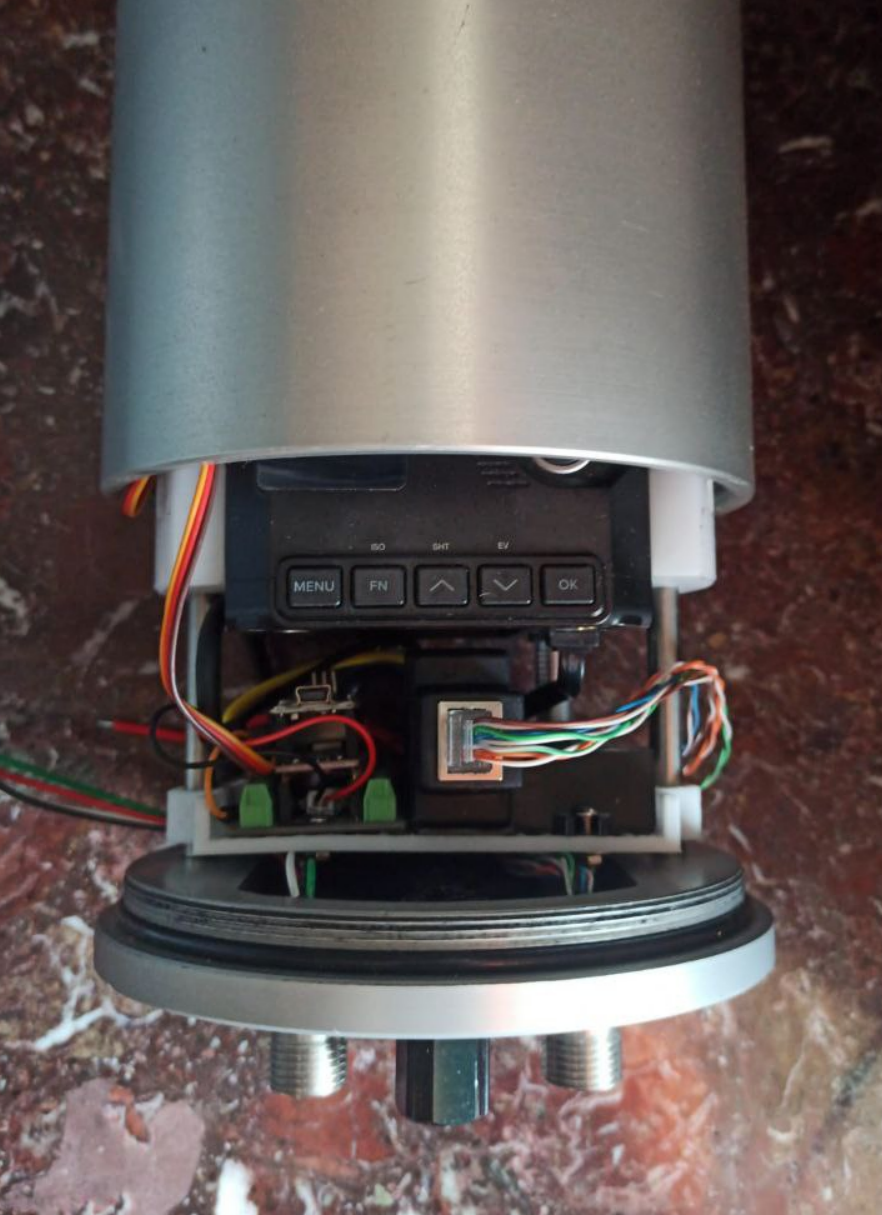
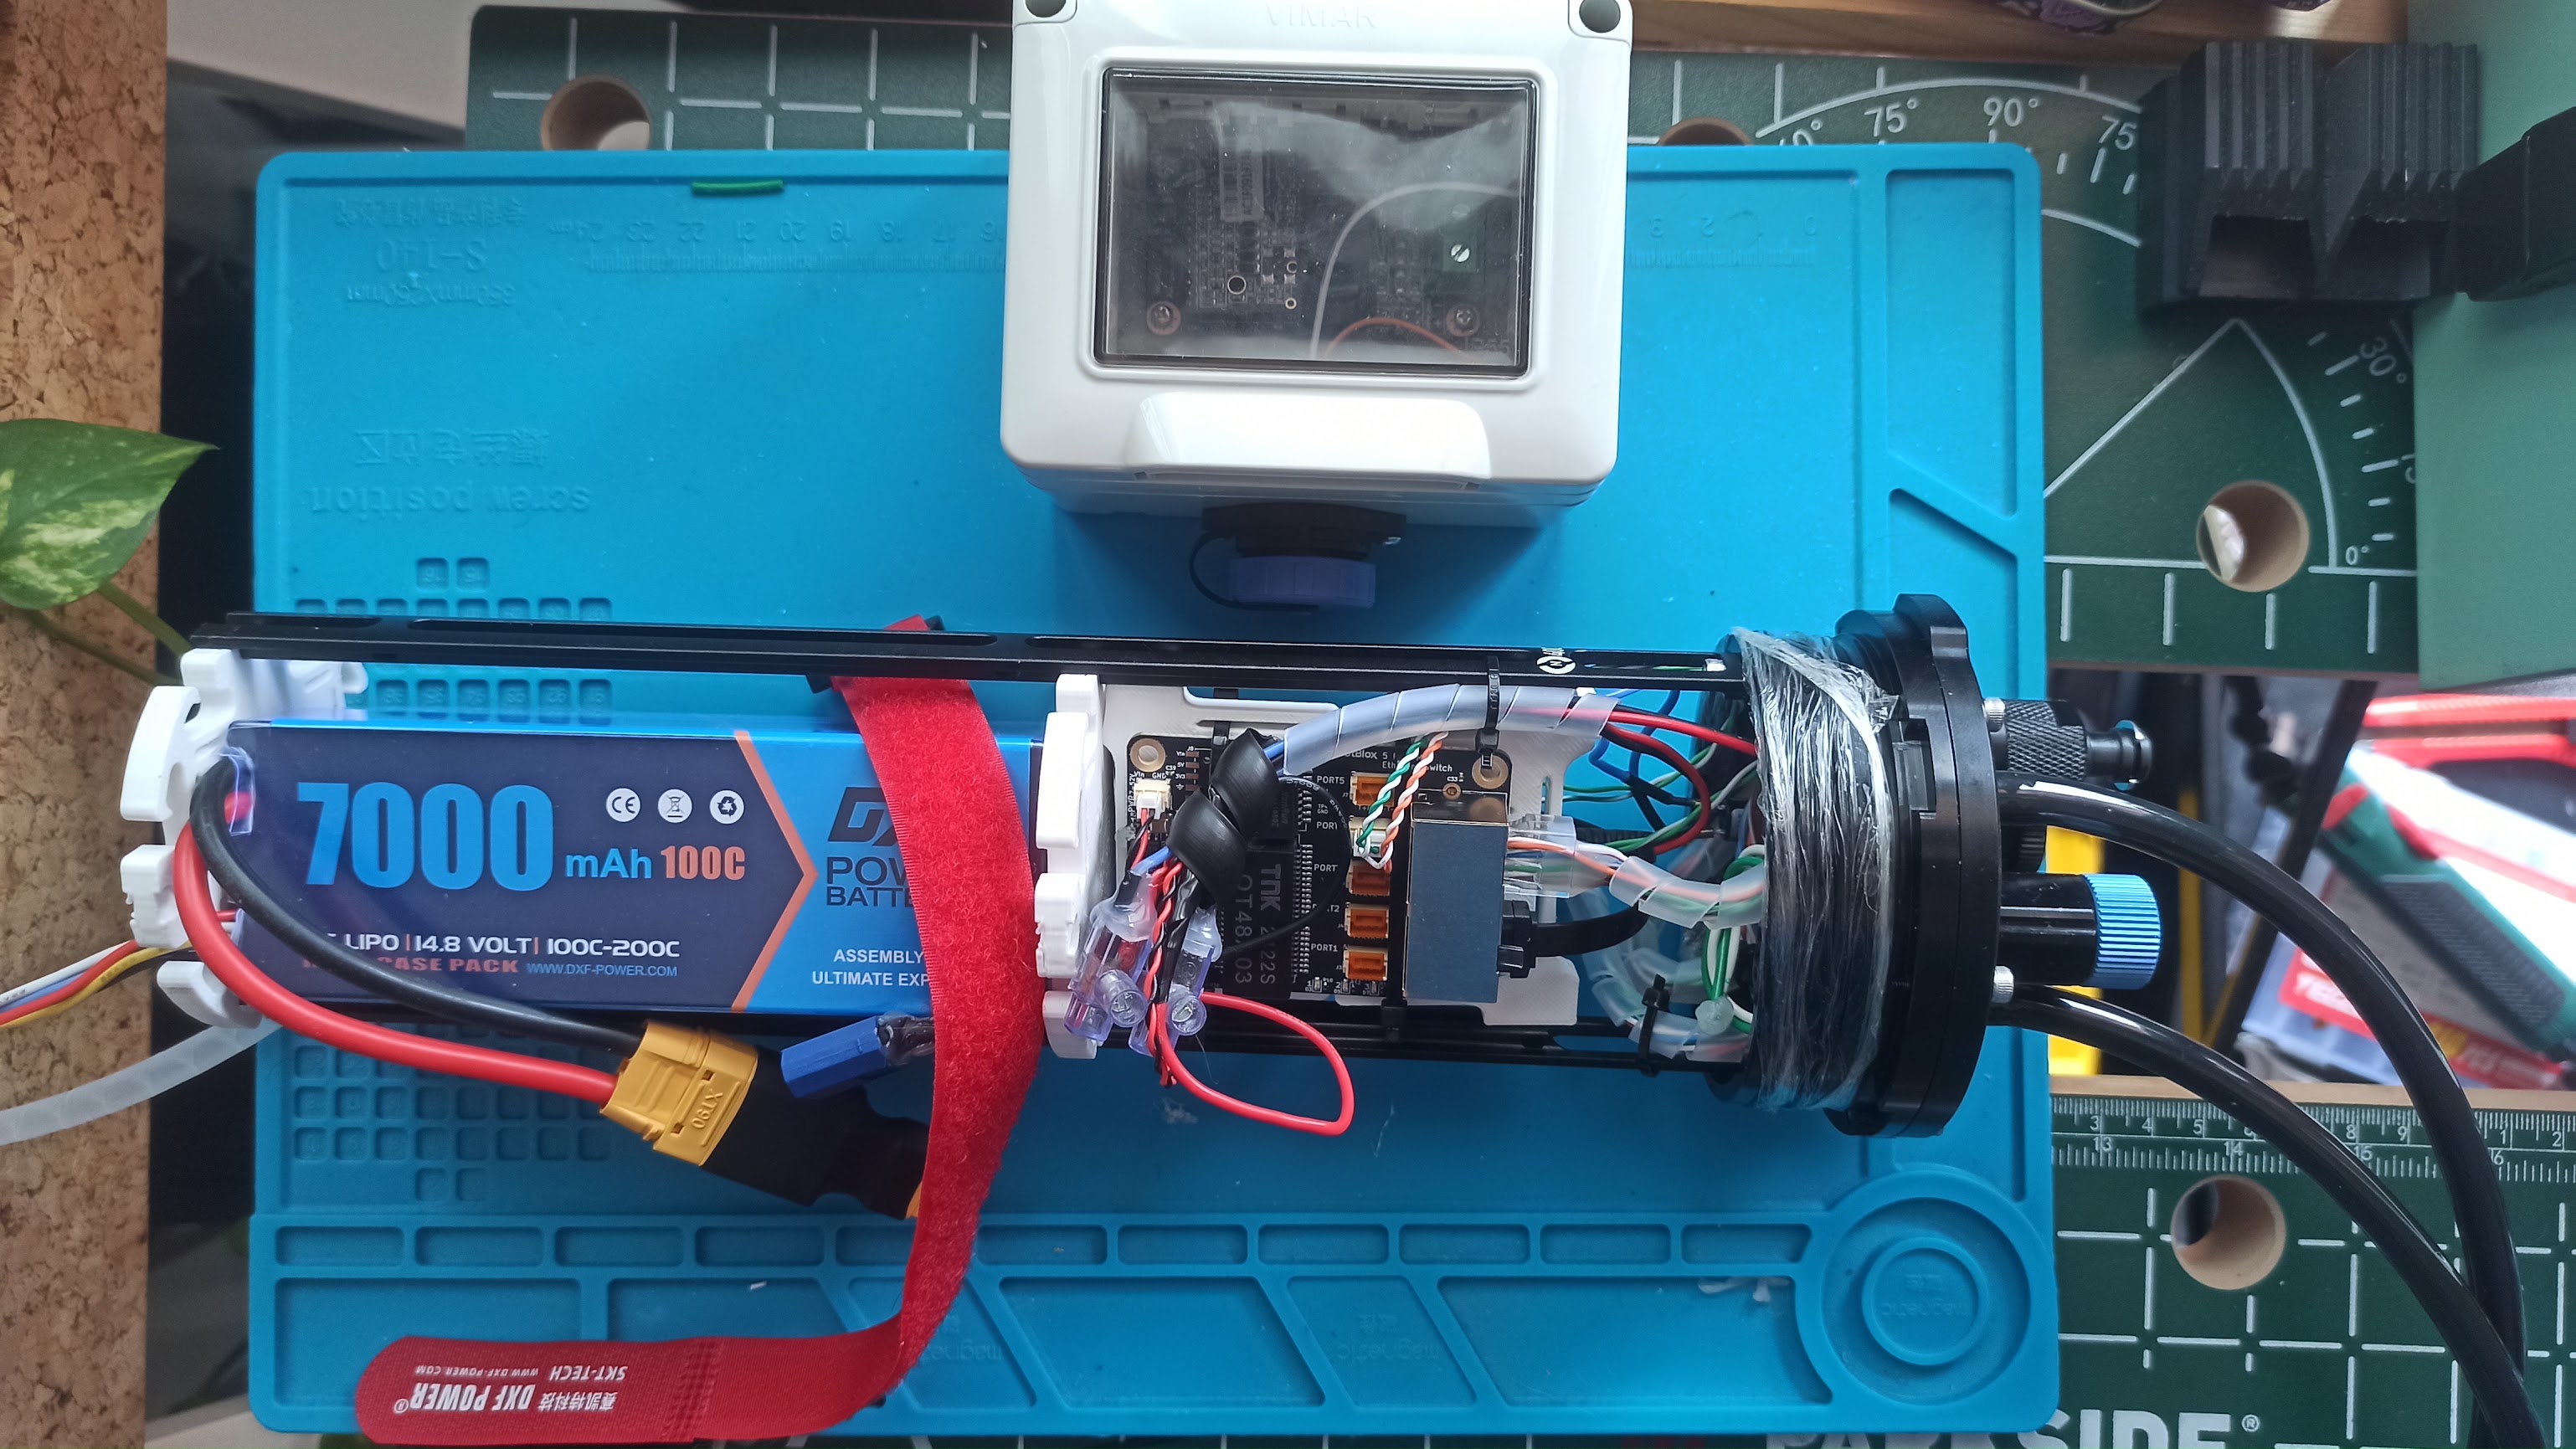
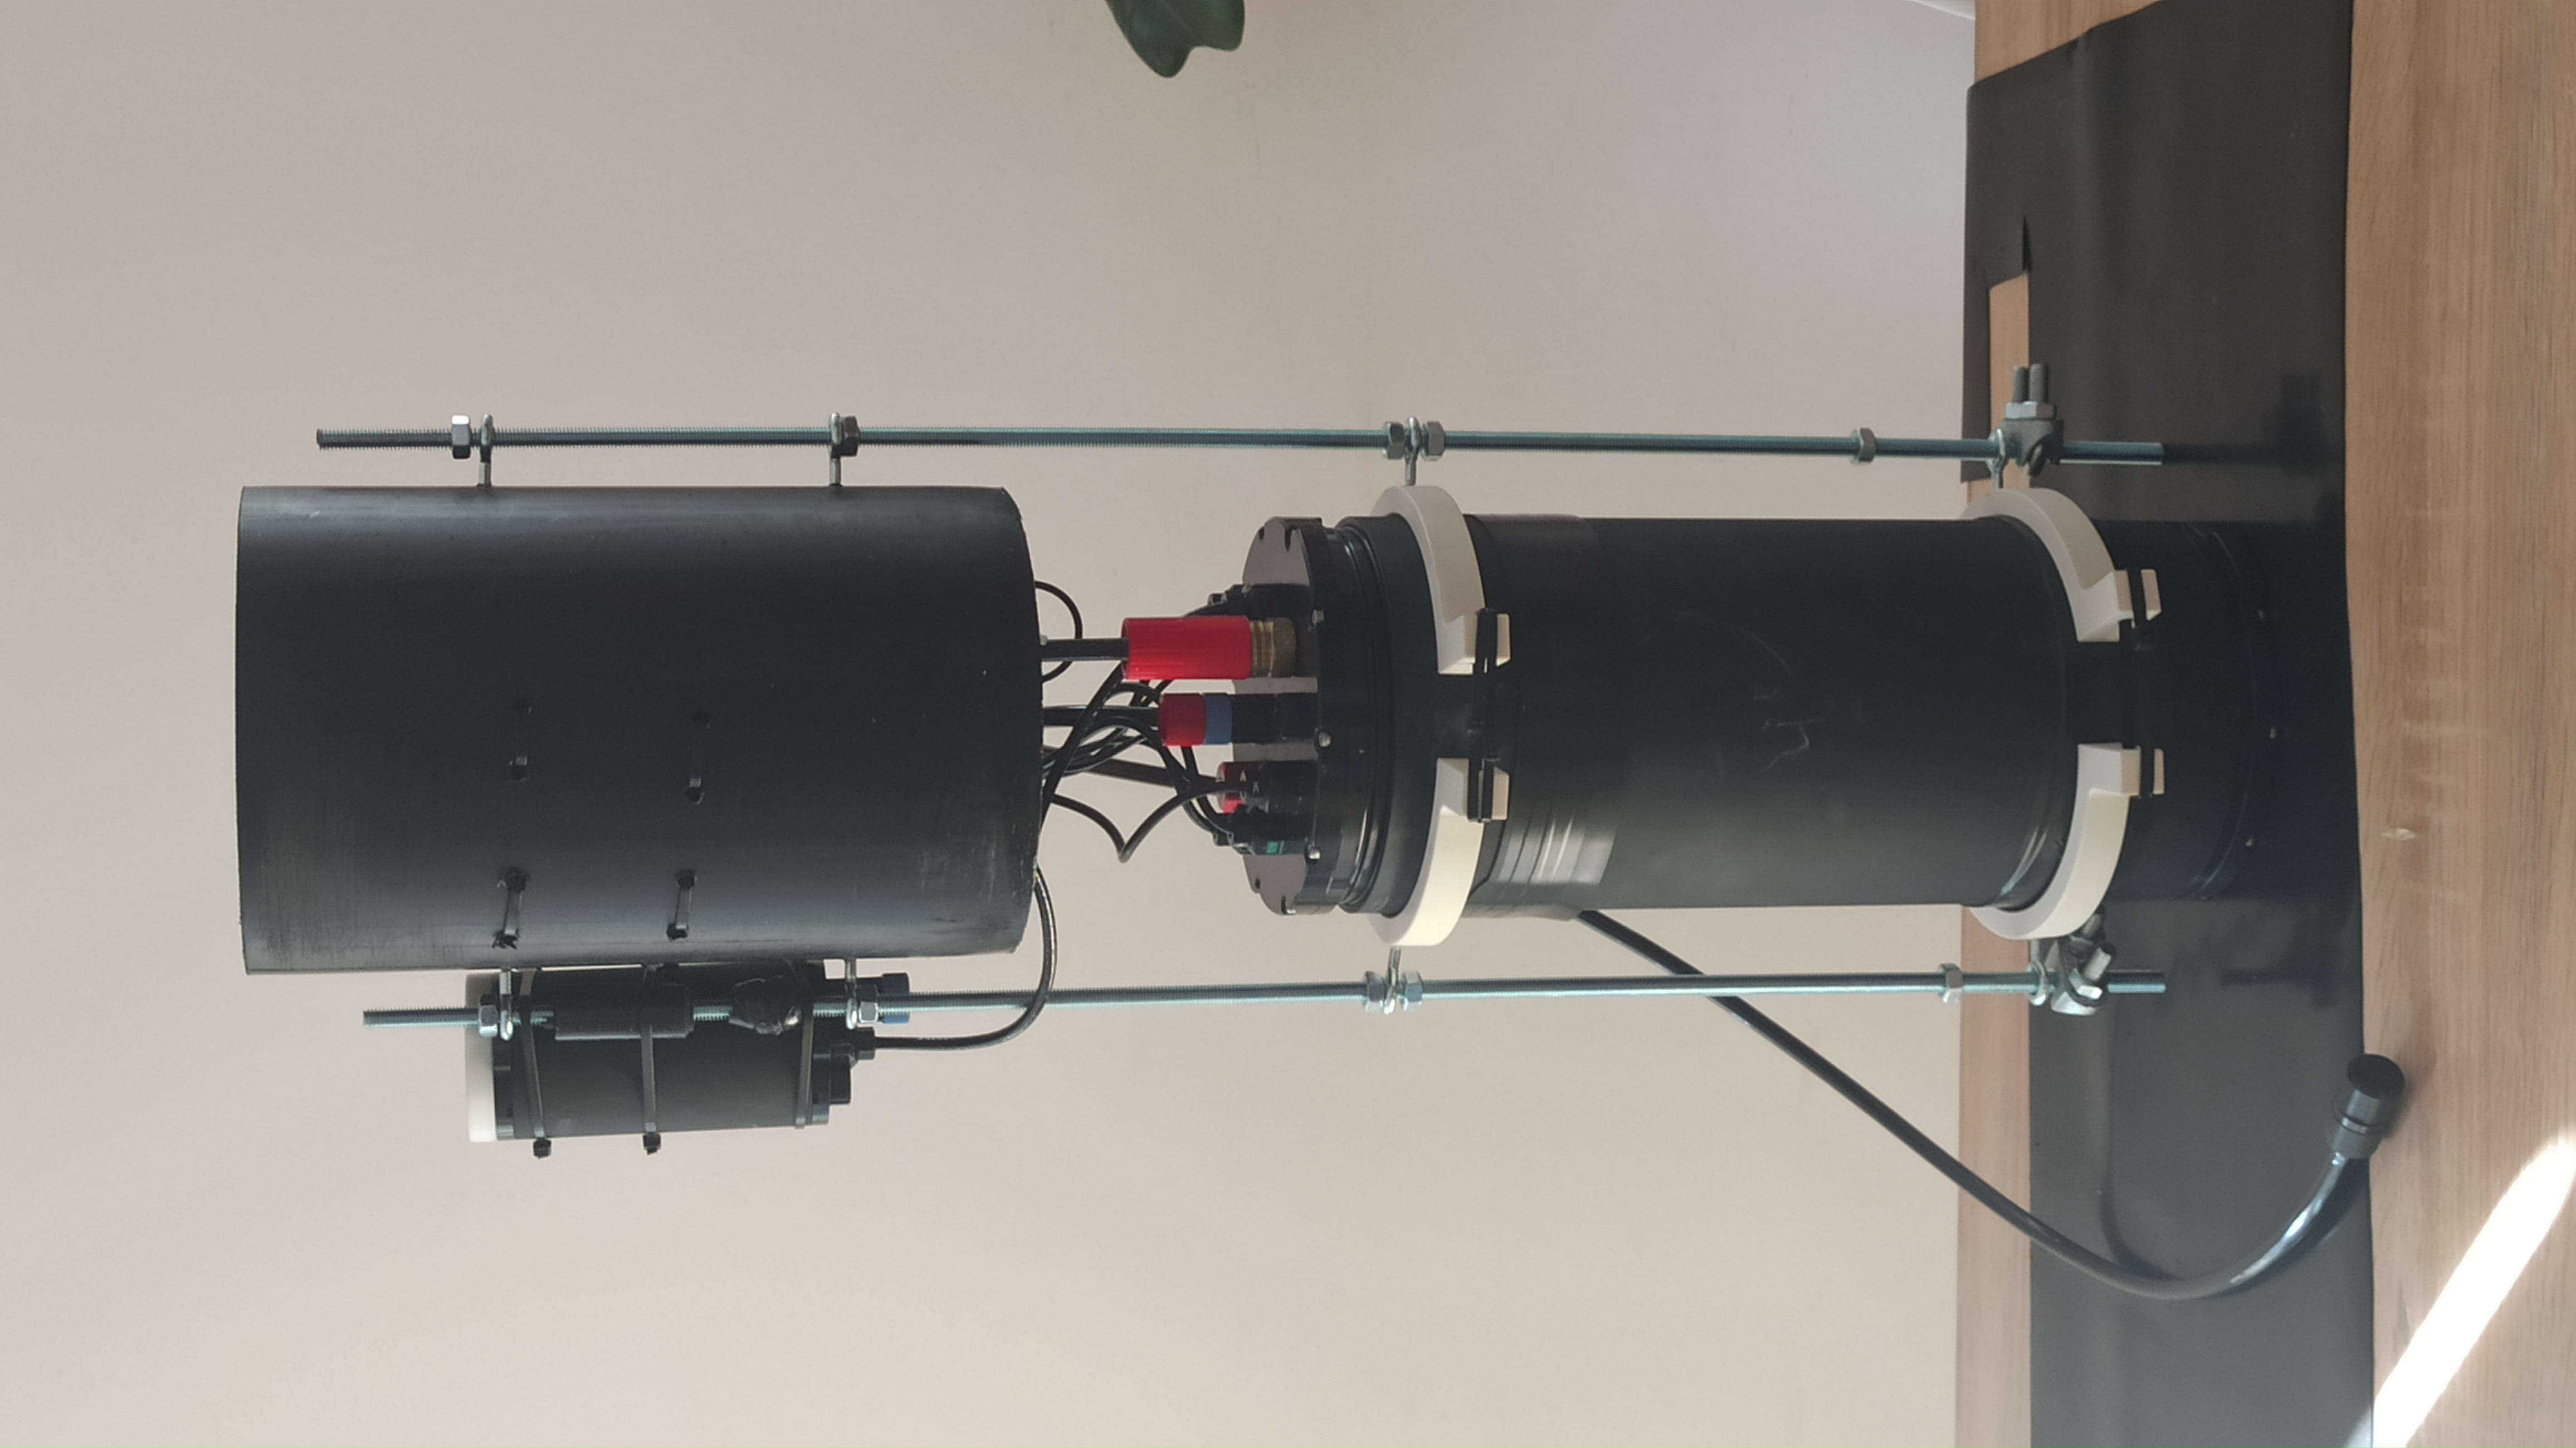
I worked across the edge and cloud boundary: preparing the Raspberry Pi and gateway workflow, integrating the sensor and camera services, adapting OPC UA data types, building the real-time dashboard and handling the operational details needed to test the system outside a single local network. The edge software stored sensor data locally as a fallback, published structured JSON messages, accepted commands for acquisition and calibration, and forwarded data toward the remote infrastructure. The camera side also included remote control, focus actuation and an underwater enclosure with power regulation, Ethernet and service bulkheads.
A recurring engineering problem was that video, telemetry and control traffic have different network needs. The design therefore kept OPC UA focused on structured data, commands and metadata while using dedicated streaming protocols for video. I also worked on buffering, deployment and connection stability so that an intermittent link or a dynamic 5G address would not make the whole mission workflow dependent on manual recovery.
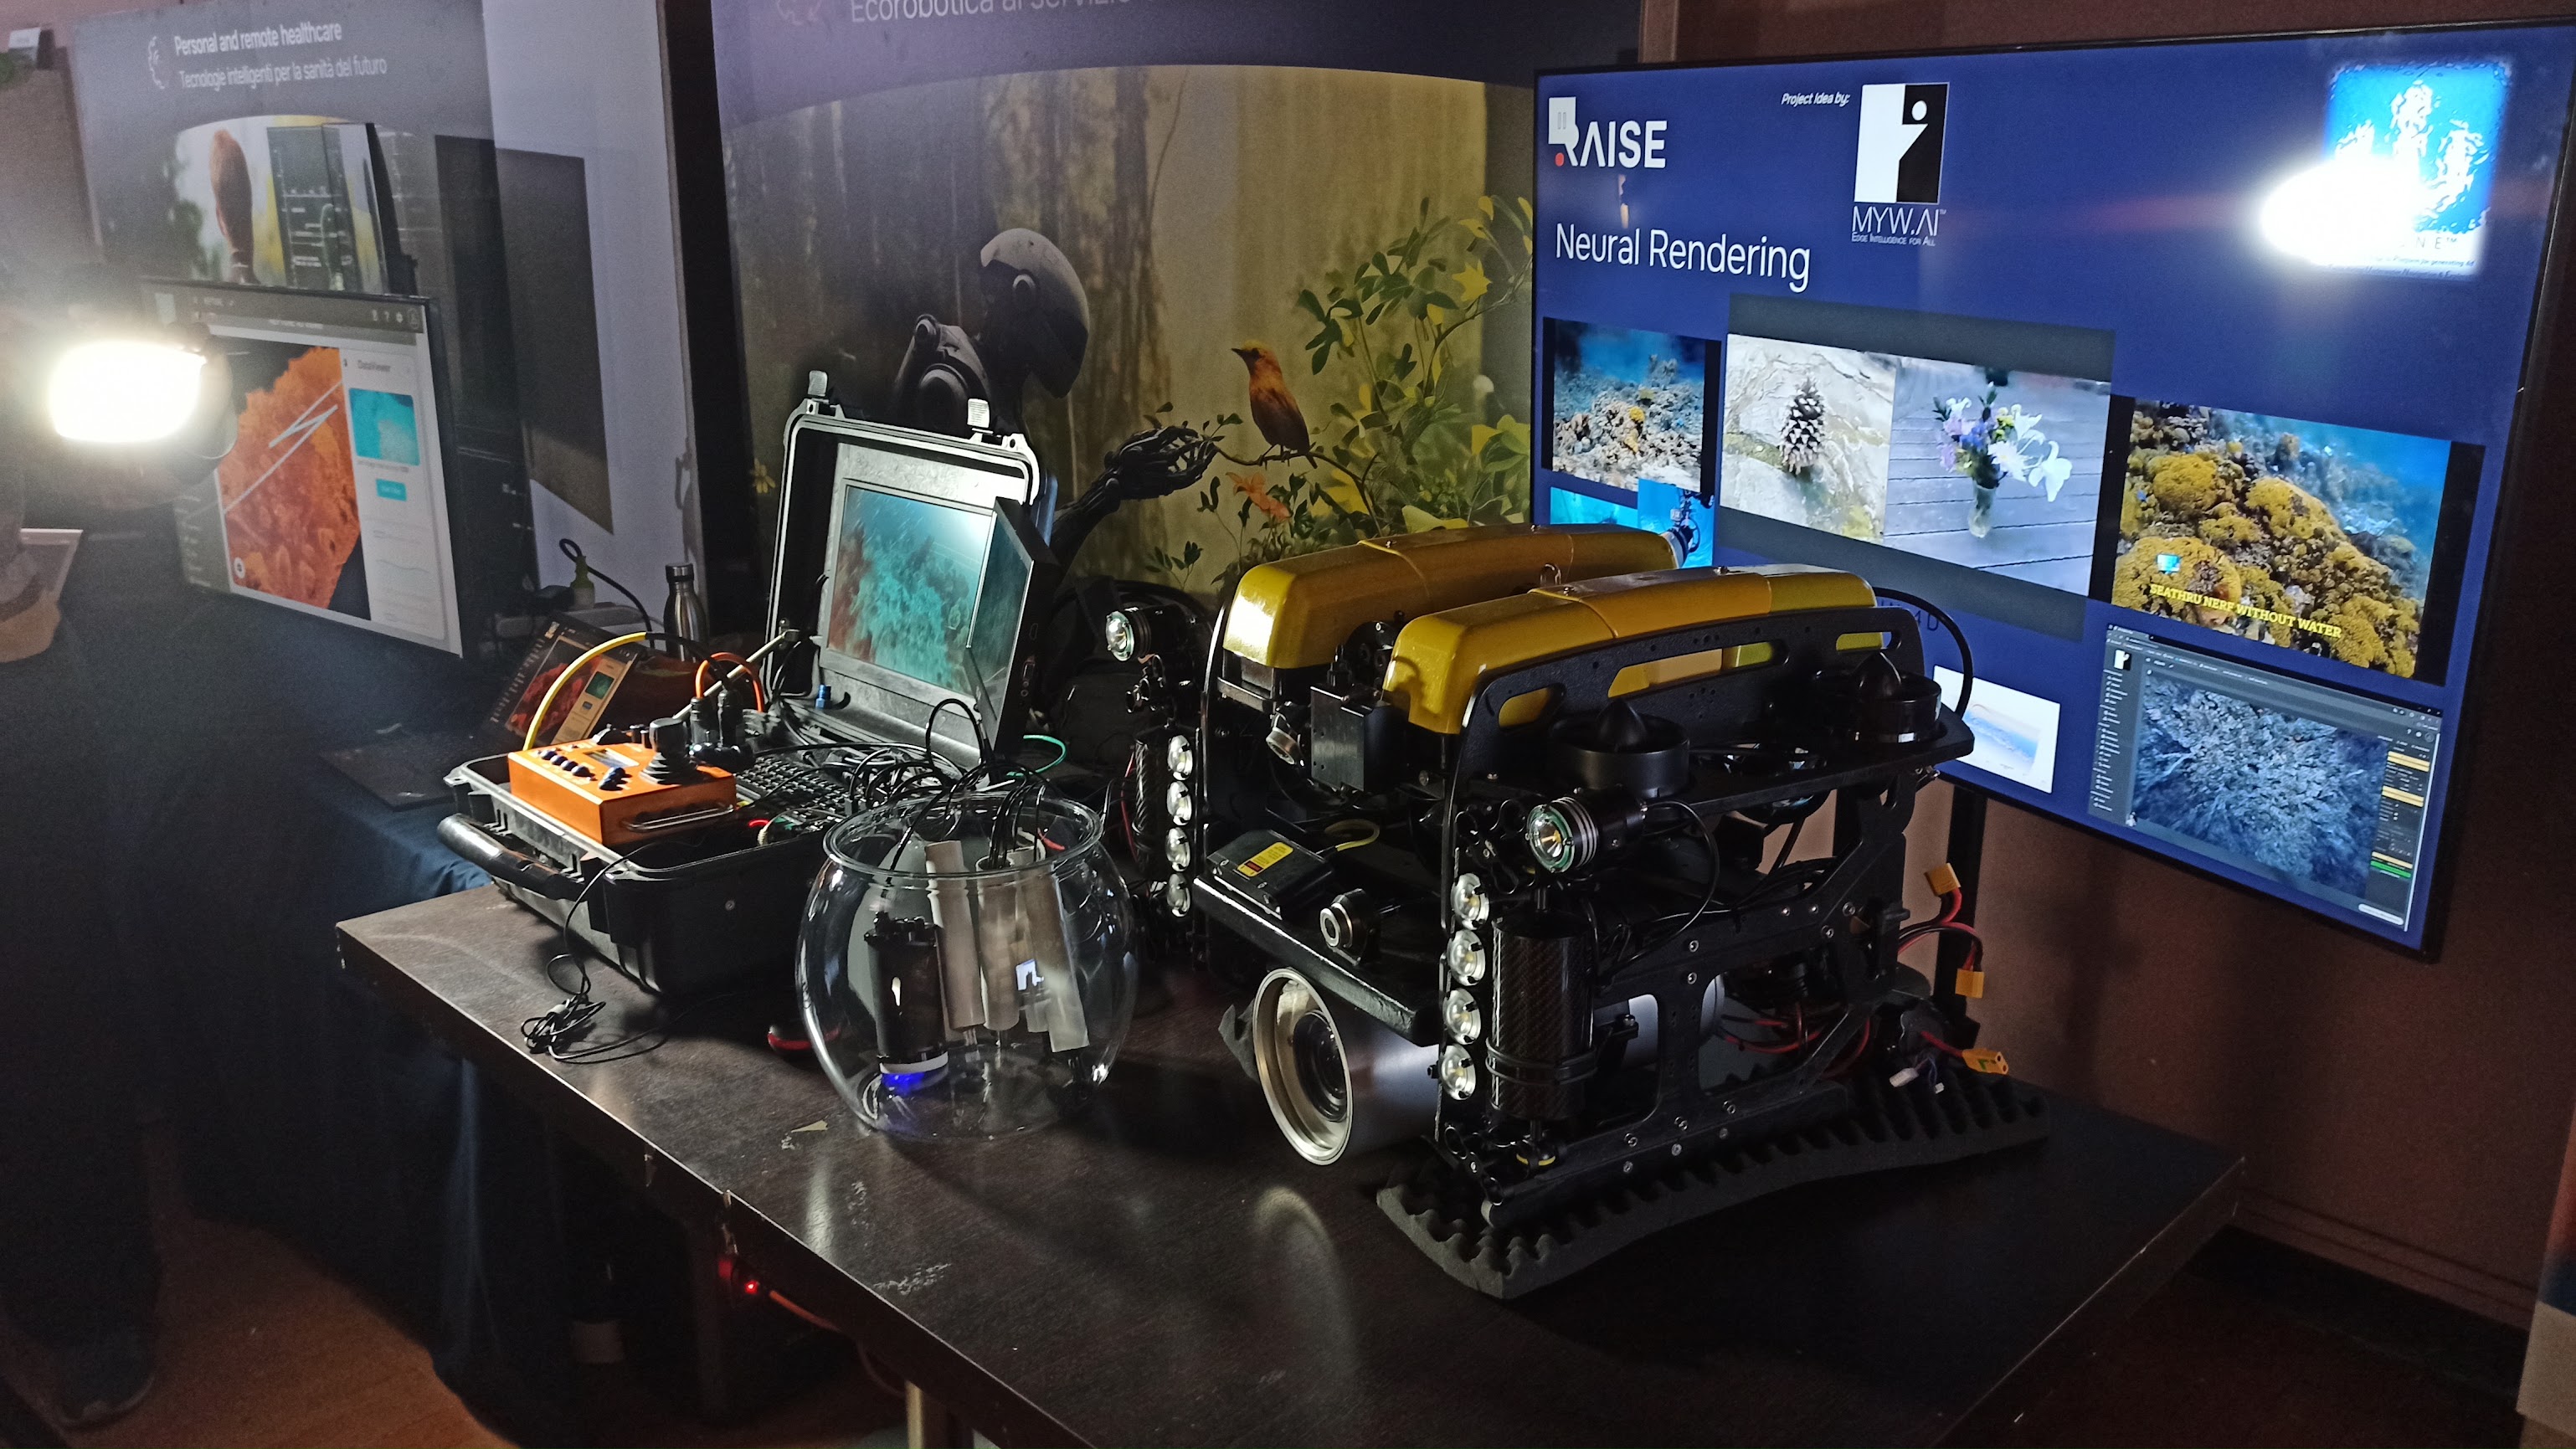
Public context: NEPTUNE was featured by RAISE in relation to the collaboration with the Area Marina Protetta di Portofino. The article describes campaigns using ROVs and DPVs equipped with cameras and environmental sensors, with the collected data contributing to evolving 4D representations of underwater sites.
Gallery